Precision Sensor & Interactive Assemblies for Reachy Mini Platforms
A humanoid desktop robot's rotational body requires low-latency telemetry, collision aversion, tactile triggers, and dynamic feedback. Below are the OEM production-line modules driving our multi-axis Reachy Mini rotational subsystems.

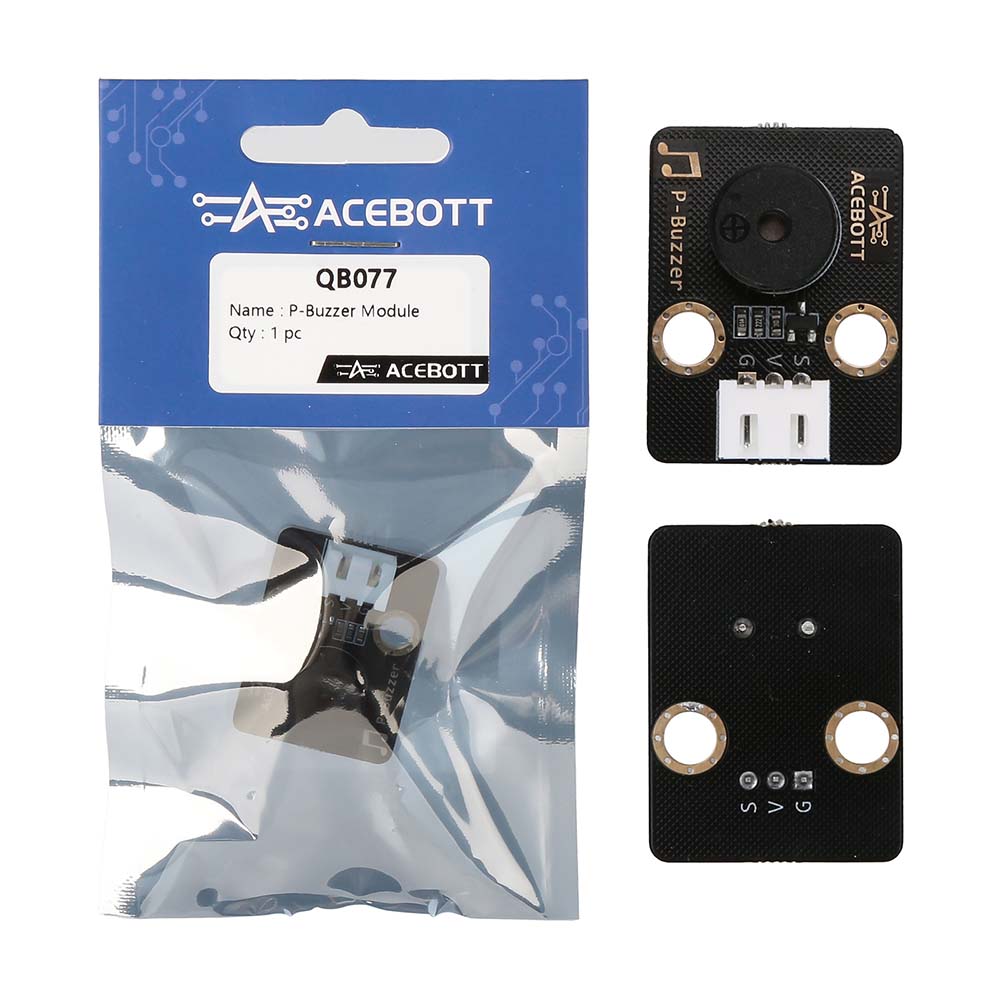
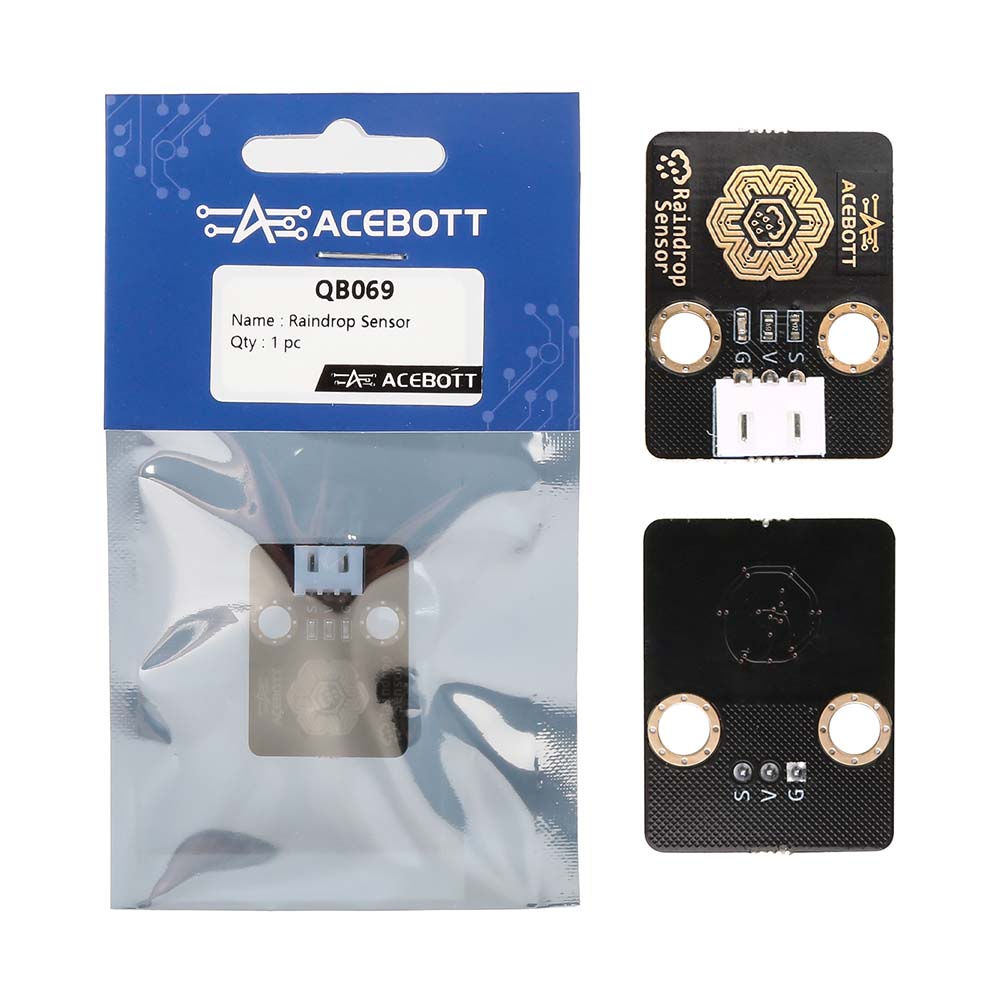

Anatomy of Axial Torso Rotation in Modern Desktop Humanoids
The desktop humanoid robotics sector has graduated from simplistic hobbyist hobby-servo swivels to industrial-grade multi-degree-of-freedom (DOF) body rotation assemblies. The Reachy Mini platform, engineered for affective human-robot interaction (HRI), bio-mimetic gesturing, telepresence, and advanced computer vision, demands zero-backlash rotational stability across its horizontal yaw axis.
When executing body rotation, dynamic inertia from the robotic upper torso, head tracking gantry, and articulated dual arms creates severe torsional deflection. Chinese precision manufacturing hubs like Shenzhen Reachybott Co., Ltd. (ACEBOTT) lead global B2B supply chains by integrating closed-loop magnetic encoders (AS5600/AS5048A), CNC aerospace-grade 6061-T6 aluminum rotation hubs, and hybrid cycloidal or planetary strain gearheads directly within the core chassis.
Through our dedicated R&D facility in Shenzhen, we solve key engineering bottlenecks: eliminates mechanical hysteresis, stabilizes current draw under continuous 360-degree rotational sweeps, and achieves sub-0.08° positioning repeat accuracy for academic and enterprise robotics developers.
| Kinematic Metric | Legacy Hobby RC Servos | Standard Planetary DC Units | Reachybott Industrial Serial Bus Yaw Actuator |
|---|---|---|---|
| Angular Resolution | 0.8° – 1.5° (Open Loop PWM) | 0.3° – 0.5° (Potentiometer) | 0.087° (12-bit / 14-bit Magnetic Feedback) |
| Gear Backlash | > 45 arcmin (Nylon/Brass) | 20 – 30 arcmin (Sintered Steel) | < 8 arcmin (Hardened 7075 / Cr-Mo Steel) |
| Continuous Torque | 12 – 18 kg·cm @ 6V | 25 – 35 kg·cm @ 12V | 45 – 70 kg·cm @ 12V–24V Sustained |
| Telemetry Protocol | None (Analog 50Hz Pulse) | Basic UART (Unidirectional) | Bi-Directional RS-485 / CAN FD Bus (1Mbps) |
| Thermal Throttling | Rapid runaway (>65°C in 12 min) | Linear decay, thermal creep | Dynamic PID Current Rollback + CNC Heatsink |
Next-Generation Sourcing Trends for Humanoid Actuators (2025–2030)
B2B robotics sourcing is moving away from fragmented sourcing to integrated kinematic module procurement. Here is how Tier-1 international institutions and OEMs are structuring their China supply chains.
Integrated Field-Oriented Control (FOC)
Procurement teams are ditching noisy trapezoidal PWM drives. Modern body rotation hubs incorporate ultra-compact FOC brushless drivers directly on the servo endplate, ensuring silent operation for classroom and hospital environments.
Daisy-Chain Serial Bus Architecture
Eliminating cable nests across multi-DOF torso joints: single-cable serial bus systems (TTL/RS485) allow 30+ actuators and secondary sensor nodes to cascade throughout the Reachy Mini spine without slip-ring mechanical fatigue.
Local AI Micro-Edge Telemetry
Modern rotational hubs are embedded with 32-bit Cortex-M4/ESP32 microcontrollers that compute localized inverse kinematics, monitor internal thermal health, and automatically trigger safety stalls during physical user interaction.
BOM Customization & Modular Platforms
Procurement executives require flexible BOM modifications: substituting metal gears for carbon-composite variants, custom wire harnesses, specialized bracket anodization, and custom open-source ROS/ROS2 driver packages.
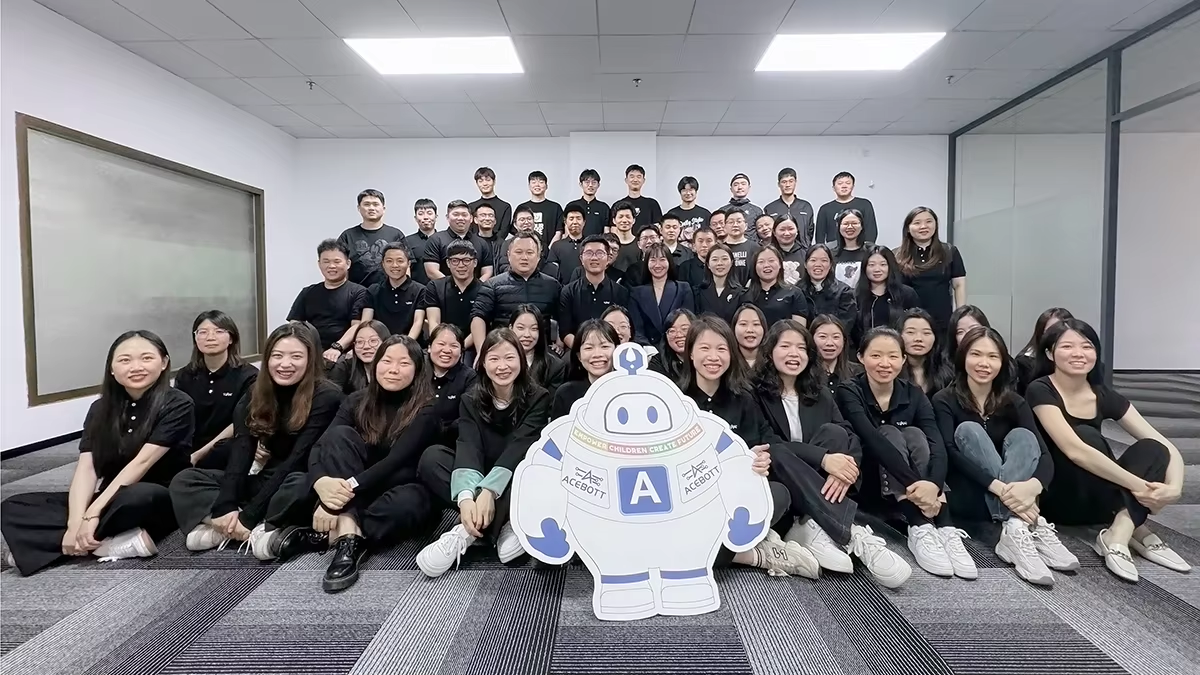
Shenzhen Reachybott: Engineering Excellence from China’s Hardware Core
Headquartered in Tairan Technology Park, Shenzhen, with high-capacity production facilities spanning over 3,000 m², Shenzhen Reachybott Co., Ltd. (brand: Reachy Mini Bot / ACEBOTT) operates as an elite manufacturer and technology exporter founded in 2013.
Our multidisciplinary team of over 150 specialists encompasses electromechanical CAD engineers, embedded firmware architects, SMT production managers, and international trade compliance officers. We maintain strict vertical integration: from PCB surface-mounting and precision gear hobbing to automated torque dynamometer testing and final assembly.
As an onsite-inspected manufacturer on Alibaba.com holding an immaculate 4.8 / 5.0 buyer satisfaction score and an annual output value exceeding US$10M, we serve school districts, academic research institutes, and commercial robotics distributors across North America, Northern Europe, Southern Europe, and Latin America.
Zero-Defect Quality Control
Every single Reachy Mini body rotation module undergoes 72 hours of uninterrupted burn-in oscillation, back EMF voltage spike suppression checks, and precise laser interferometer angular verification.
Full OEM/ODM Flexibility
We provide full white-label customization including custom gear ratios, high-temp silicone wiring, bespoke mounting brackets, custom silkscreen branding, and turnkey multi-language instructional kits.
Direct Global Logistics Hub
Direct export channels supporting FOB, CIF, EXW, DDP, and DDU incoterms. Streamlined customs documentation with full CE, FCC, RoHS, and REACH international market certifications.
Frequently Asked Questions on Reachy Mini Body Rotation Procurement
In-depth technical and commercial answers addressing mechanical tolerances, protocol architecture, sample prototyping, and bulk contractual assurances.
What internal gear train mechanism is optimal for the Reachy Mini torso yaw rotation? +
For high-frequency bi-directional body rotation, our factory strongly recommends hardened steel and aerospace-grade 7075-T6 aluminum composite cycloidal or multi-stage planetary gear trains over conventional spur gears. Standard plastic or pure brass spur gears suffer excessive tooth wear under rapid acceleration profiles, causing angular backlash to deteriorate beyond 30 arcminutes within 200 operational hours. Reachybott’s proprietary gear formulation delivers continuous operating backlash under 8 arcminutes with a mechanical lifespan exceeding 5,000 continuous hours.
How does Reachybott mitigate thermal drift and overheating during sustained torso yaw sweeps? +
Thermal management is built into our hardware and firmware layers. Structurally, our rotation modules integrate CNC-machined 6061 aluminum alloy shells serving as passive heat sinks for motor stators and MOSFET bridges. Electrically, our driver boards run real-time thermistor monitoring with dynamic PID current rollback: if junction temperatures exceed 75°C, the controller subtly modulates maximum continuous holding torque rather than violently triggering sudden shutdowns, safeguarding robot balance and continuous operation.
Can our engineering team specify custom communication protocols (CAN FD vs. RS-485 vs. TTL UART)? +
Yes. While educational STEM packages typically default to half-duplex high-speed TTL serial bus (up to 1Mbps) for straightforward Arduino/ESP32 integration, our industrial and university-grade clients can request native RS-485 differential signaling or CAN 2.0B / CAN FD. We supply dedicated C++ libraries, ROS/ROS2 drivers, and Python SDK bindings compatible with Linux, Raspberry Pi, and NVIDIA Jetson host controllers.
What is your Minimum Order Quantity (MOQ) for prototypes versus customized OEM production? +
For standard evaluation units and off-the-shelf Reachy Mini body rotation developer kits, our MOQ is exactly 1 unit to facilitate quick pilot bench testing and academic research validation. For OEM/ODM customization—including custom bracket geometry, laser logo branding, custom wire lengths, or bespoke gear ratios—our standard production run starts at 100 to 500 units depending on tooling requirements, with turnaround times as fast as 15–20 business days.
How are external interactive sensors integrated alongside the central body rotation module? +
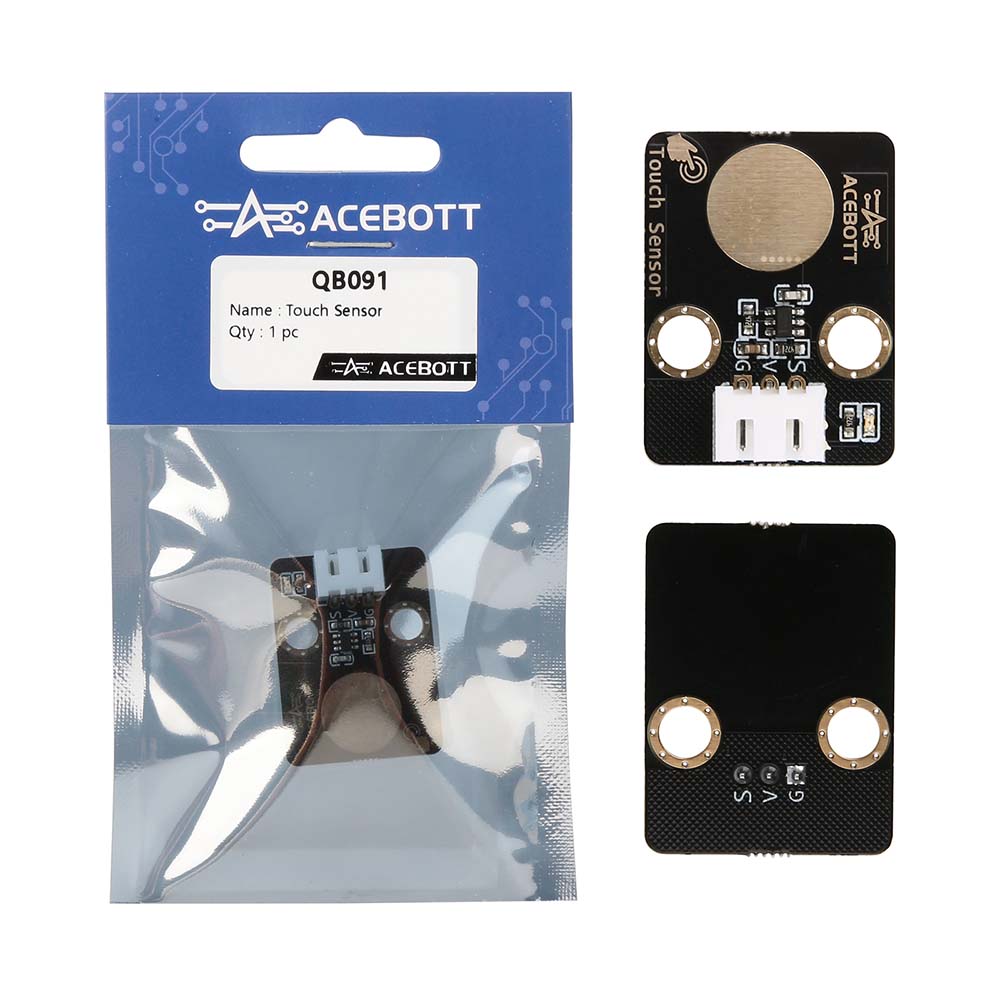
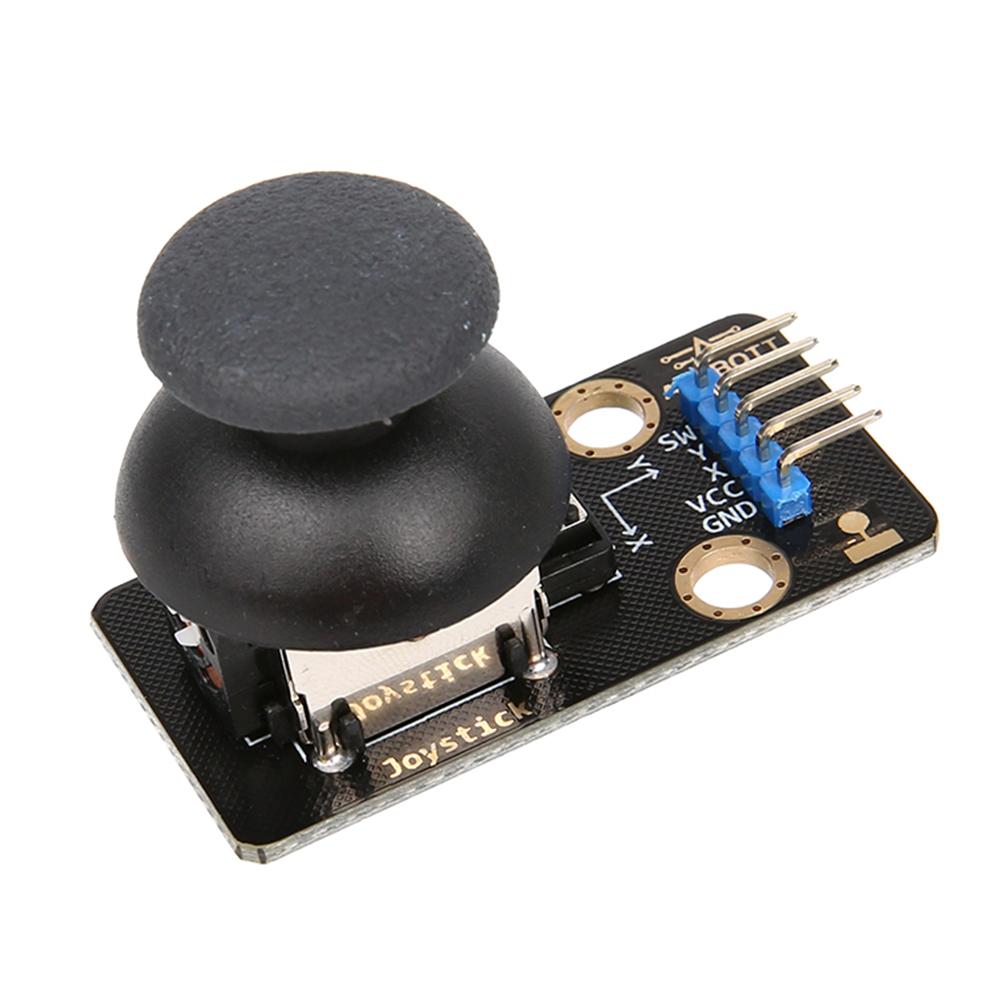
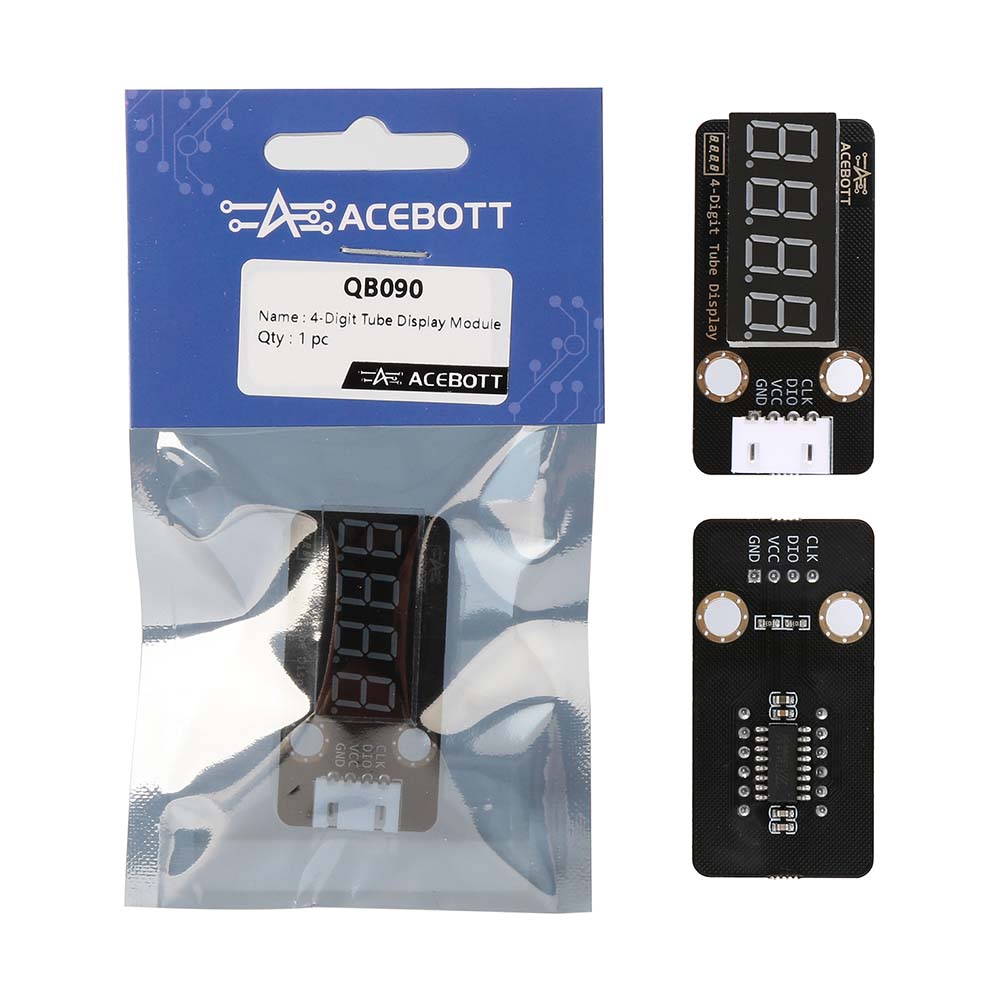
The 8 featured modules in our portfolio—ranging from TTP223B capacitive touch sensors and obstacle-avoidance IR receivers to TM1637 displays and dual-axis PS2 analog joysticks—connect directly to the auxiliary peripheral buses of our primary ESP32 robot breakout hub. Cable management passes through an internal hollow-shaft axial slip ring located inside the torso yaw bearing, preventing wire twist and wear regardless of rotational angle.
What quality assurance certifications and testing routines back your production batches? +
Our Shenzhen manufacturing facility operates under an ISO9001-certified quality control regime. All rotational actuators and electronic sub-assemblies undergo 100% automated optical inspection (AOI) on the SMT lines, full dynamic load dynamometer testing, stall torque verification, and electromagnetic compatibility testing. All shipped items comply with CE (EMC/LVD), FCC Part 15 Class B, RoHS 2.0, and REACH environmental standards.
Request Technical Specifications or Custom Quotations
Whether you require sample units for kinematic evaluation, customized gear ratios for academic lab research, or high-volume private label manufacturing for robotics curricula, our Shenzhen engineering and export team is on standby to assist.